← Back to Products

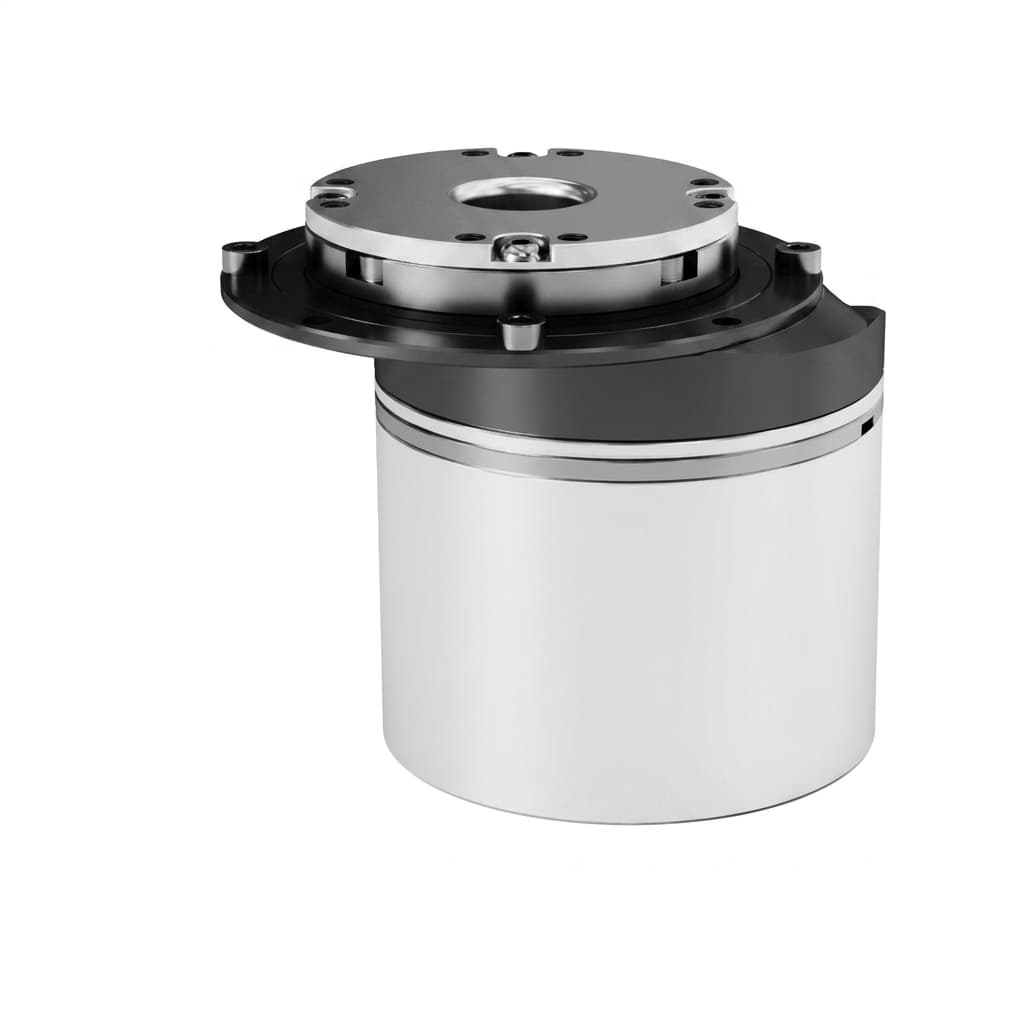
Compact Planetary Joint Module

Compact planetary-reducer joint module balancing torque density, response speed, and cost for collaborative and mobile robot applications.
Target Buyer:Best for teams balancing performance, compactness, and scalable procurement economics.
Compact planetary robot joint module

Capability Highlights

  • Balanced cost-to-performance architecture
  • Compact footprint for distributed multi-axis systems
  • Good dynamic response for frequent acceleration changes

Typical Applications

  • Collaborative robot joints
  • AGV/AMR manipulator modules
  • Educational and service robots

Engineering Focus

  • Backlash allowance by end-effector precision requirement
  • Continuous thermal operation at medium-load duty
  • Controller and communication stack compatibility

Key Evaluation Matrix

MetricTypical RangeWhy It Matters
Torque DensityMid-to-high for compact classAffects payload capability while preserving envelope constraints.
Response BandwidthApplication dependentImpacts smoothness and stability during rapid trajectory updates.

Technical Specification Baseline

Use this baseline for first-pass engineering comparison before requesting model-specific files.

FieldBaseline ValueInterpretation Note
Supply Voltage24-48V DCMatched to collaborative/mobile robot stack.
Continuous / Peak TorqueCompact planetary classBalanced by speed response and precision target.
Max Speed (No-load reference)High dynamic response classFinal value depends on control mode and payload.
Backlash ClassApplication-specificTolerance stack-up reviewed in pre-RFQ stage.
CommunicationEtherCAT / CAN optionsIntegration manual provided by project scope.

Performance Evidence

Detailed torque-speed envelopes and dynamic response evidence are provided in model-level engineering packages. Interpretation is tied to duty cycle, thermal constraints, and interface assumptions.

  • Torque-speed boundary interpretation is valid only with matched ambient and duty assumptions.
  • Response stability conclusions require controller and protocol scope alignment.
  • Final acceptance uses customer-approved sample validation criteria.

RFQ Checklist

  1. Cycle profile and target takt time
  2. Accuracy / repeatability acceptance threshold
  3. Protocol and power architecture details
  4. Prototype quantity and commercialization timeline

Risk Controls

  • Precision target incompatible with backlash class: Run pre-RFQ tolerance stack-up and upgrade to harmonic path when required.
  • Protocol mismatch with host controller: Freeze communication requirements before sample BOM lock.

Interface Drawings and Engineering Files

Request model-level STEP files and datasheets through the engineering resource workflow to ensure revision consistency.
This resource is delivered through engineering review to keep revision accuracy. For urgent requests, email [email protected].

Product Gallery

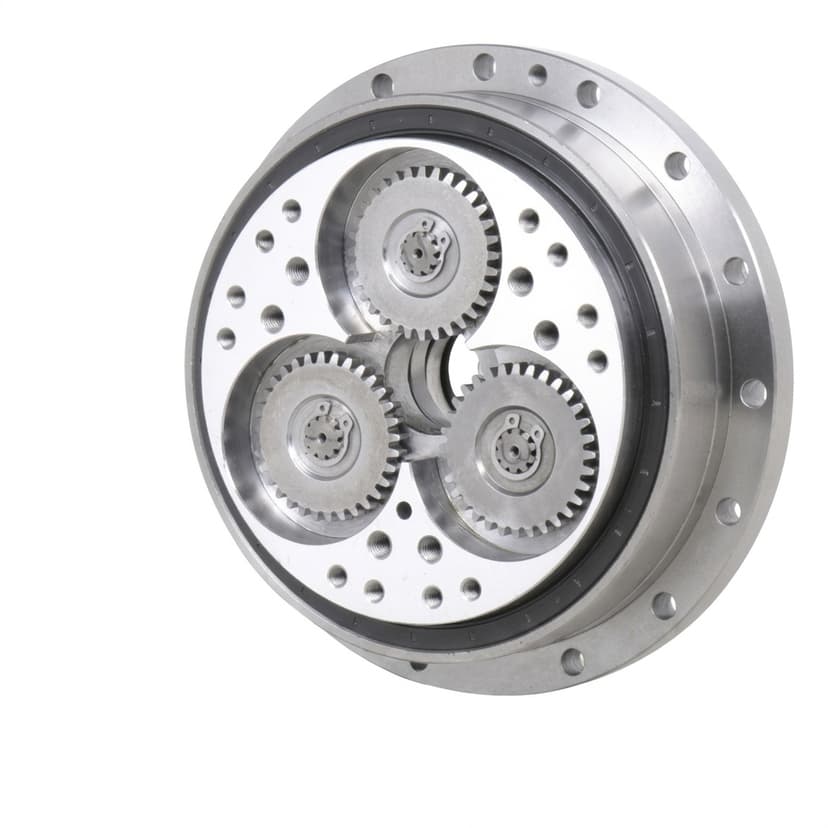
Compact robot reducer architecture for multi-axis systems
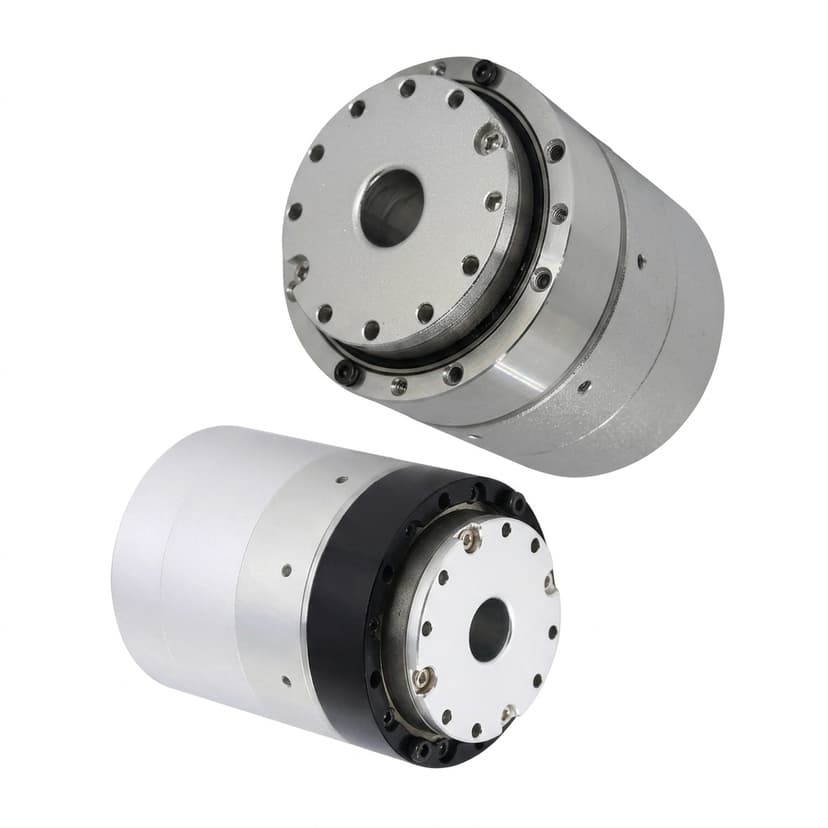
Compact actuator module used in robotic arm joints

Compliance Trust Signals

  • CE / RoHS support scope available by project baseline.
  • Quality-system evidence aligned to RFQ document checklist.
  • Functional safety assumption alignment documented during integration planning.
View Quality & Compliance Center

Buyer FAQ

Is this suitable for multi-axis collaborative robots?

Yes. It is frequently selected for compact multi-axis architectures with moderate payload requirements.

Can we start from prototype and scale later?

Yes. We support prototype-to-mass-production transition with revision traceability.

Related Resources

Engineering RFQ Email

[email protected]

Include torque-speed targets, annual volume, and timeline.

Lead Robotics Engineer

+86 18857971991

Direct technical conversation with our lead robotics engineer.