Electric rotary actuator guide

12V electric rotary actuator sizing and RFQ

Check 12V torque, current, voltage drop, and duty cycle. For a 12V hollow rotary actuator, verify bore and cable clearance in its drawing.

12V rotary actuator quick check

Size a 12 volt electric rotary actuator profile

Enter the working load case to see whether 12 VDC is a reasonable starting point or whether the same electric rotary actuator requirement should move to 24/48 VDC or custom engineering review.

Sizing assumptions

12 VDC is common for compact or mobile low-voltage systems.

Supported quick range: 5-500 Nm.

Use 90, 180, or 360 for common strokes.

High duty raises motor and gearbox thermal risk.

Used to estimate current from P = V x I.

Long 12 VDC runs need round-trip voltage-drop review.

Used only for first-pass copper voltage-drop screening.

Waiting for input

Default values are prefilled for a compact 12 volt electric rotary actuator scenario. Calculate to reveal fit, risks, and next action.

Report summary

Core conclusions for 12V and general electric rotary actuator selection

Treat 12 VDC as an electrical requirement, then check whether the named actuator meets the required torque, speed, travel, duty, and installation envelope. Use the calculator for a first-pass screen; confirm model ratings and operating conditions before selecting hardware.

Evidence boundary: this page separates source-backed conclusions from model-specific values that still require datasheet or supplier confirmation, including explicit 12V mini hollow boundaries.

Engineering review updated September 30, 2026.

12 VDC

At equal input power, a 12 VDC system draws more current than a 24 or 48 VDC system.

For the same electrical input watts, 12 VDC needs twice the current of 24 VDC. Cable resistance, connector ratings, and duty cycle still determine whether the installation is workable.

model

The supply label alone does not establish torque or speed at the output.

Check the exact model’s torque-speed curve, current limit, gearing, brake, and thermal limits against the application load.

mini-hollow

A “12v dc mini hollow rotary actuator” should be screened as a compact, model-specific hollow-bore variant.

Public mini hollow examples publish bore, torque, speed, gear ratio, and voltage by exact model. Treat small-bore figures such as 5.2-13.5 mm and torque examples such as 1.8-28 Nm as shortlist evidence that still requires datasheet and winding confirmation.

4 checks

Torque, speed, inertia, and duty cycle must be checked together.

Oriental Motor selection references require load inertia, required torque, speed, and acceleration torque checks for rotary motion.

P = I x V

Lower voltage raises current for the same electrical power.

OpenStax states electric power as current times voltage, so a 12 VDC system needs twice the current of 24 VDC at the same input watts.

90°

A 90 degree label is a travel signal, not proof of a common mechanical interface.

ISO 5211:2026 covers part-turn actuator attachments for industrial valves; robot joints, dampers, and compact gearmotor packages need different interface proof.

7 inputs

Supplier selection needs application evidence, not only catalog voltage.

Tolomatic lists orientation, distance, load, force, move time, cycle rate, and environment as basic electric actuator selection inputs.

OSHA

Low voltage does not remove machine and robot safety duties.

OSHA robot guidance warns that unexpected movement, stored energy, restricted-space work, and component malfunction remain hazards around actuators and end effectors.

model-specific

Premium hollow actuator voltage must be confirmed by exact model.

Public mini hollow actuator examples often publish specific supply, torque, speed, and gear-ratio limits. Do not infer native 12V compatibility without the exact datasheet or a custom winding confirmation.

transient

Transient motor current can create brown-out risk in 12V systems.

Stall and startup current are model-specific. The page treats bulk capacitance, isolated logic power, soft-start, connector resistance, and oscilloscope validation as RFQ checks rather than universal numeric guarantees.

Selection checks

How voltage, travel, and package size change actuator selection

These requirements change the checks and evidence needed for a shortlist. None of them establishes that a particular model will meet the application load.

RequirementWhat it changesWhat to verify
12 VDC supplyLower supply voltage raises current for the same input power and makes cable drop more significant.Peak and continuous current, driver limit, fuse, connector rating, cable length, and terminal voltage.
90 degree travelTravel angle does not specify travel time, stop accuracy, or the mechanical interface.Motion profile, breakaway and running torque, mounting pattern, shaft interface, and end-stop behavior.
Hollow shaftA pass-through competes for space with wiring, slip rings, seals, and the output structure.Bore drawing, cable outside diameter, bend radius, strain relief, rotation range, and slip-ring ratings.
Micro packageA smaller envelope can constrain torque, bearing loads, heat rejection, and service life.Exact outline drawing, combined bearing loads, torque-speed curve, thermal limits, and duty-cycle rating.

Hollow Shaft Integration

12V hollow rotary actuator bore, cable routing, and slip ring checks

A key mechanical variant for the 12v dc mini hollow rotary actuator is the hollow shaft itself, which allows wires, slip rings, lasers, or pneumatics to pass through. Sizing must account for mechanical clearance limits and slip ring contact resistance to ensure system longevity.

Stator / DriveStator / DriveSlip RingRotating Hollow Shaft (mini through-bore to large table class)Stationary Outer HousingStationary Outer HousingCables Pass-Through (Laser / Air / Control Harness)
Hollow aperture sizeRecommended slip ring capsuleTypical application pathRouting and current limits
Ø5.2 mm - Ø13.5 mm public mini-bore example classUsually direct pass-through or a vendor-matched micro capsule selected for the required circuits and signal typeDirect cable pass-through for small sensor, fiber optic, or laser paths in tight envelopesConfirm bore size, wire gauge, cable OD, bend radius, and the slip-ring supplier’s dynamic resistance and signal-transmission limits for the required 12 VDC circuit.
Ø11 mm - Ø19 mm compact hollow boreMini capsule slip ring only after circuit and current reviewDC power (sensor grade) and encoder signal pass-throughSeparate motor power from encoder or fieldbus signals, specify shielding and twist requirements, and confirm torsion-rated cable bend radius with the cable supplier.
Ø20 mm - Ø33 mm compact table classStandard capsule or through-bore slip ring if rated for dutyMulti-axis robot wrist power (5A-10A) and EtherCAT feedthroughUse shielded twisted pairs for communication, separate power and signal paths, and request slip-ring dynamic contact resistance and life data for the target current.
Ø50 mm - Ø100 mm large table classLarge hollow slip ring after pneumatic, fluid, and current reviewHeavy automated index tables with pneumatic, vacuum, and high-power linesDefine fluid or pneumatic line size, conductor temperature, signal isolation, service loop, rotation duty, and inspection access before treating the bore as usable capacity.

Evidence upgrades

What this report verifies before you shortlist a 12V actuator

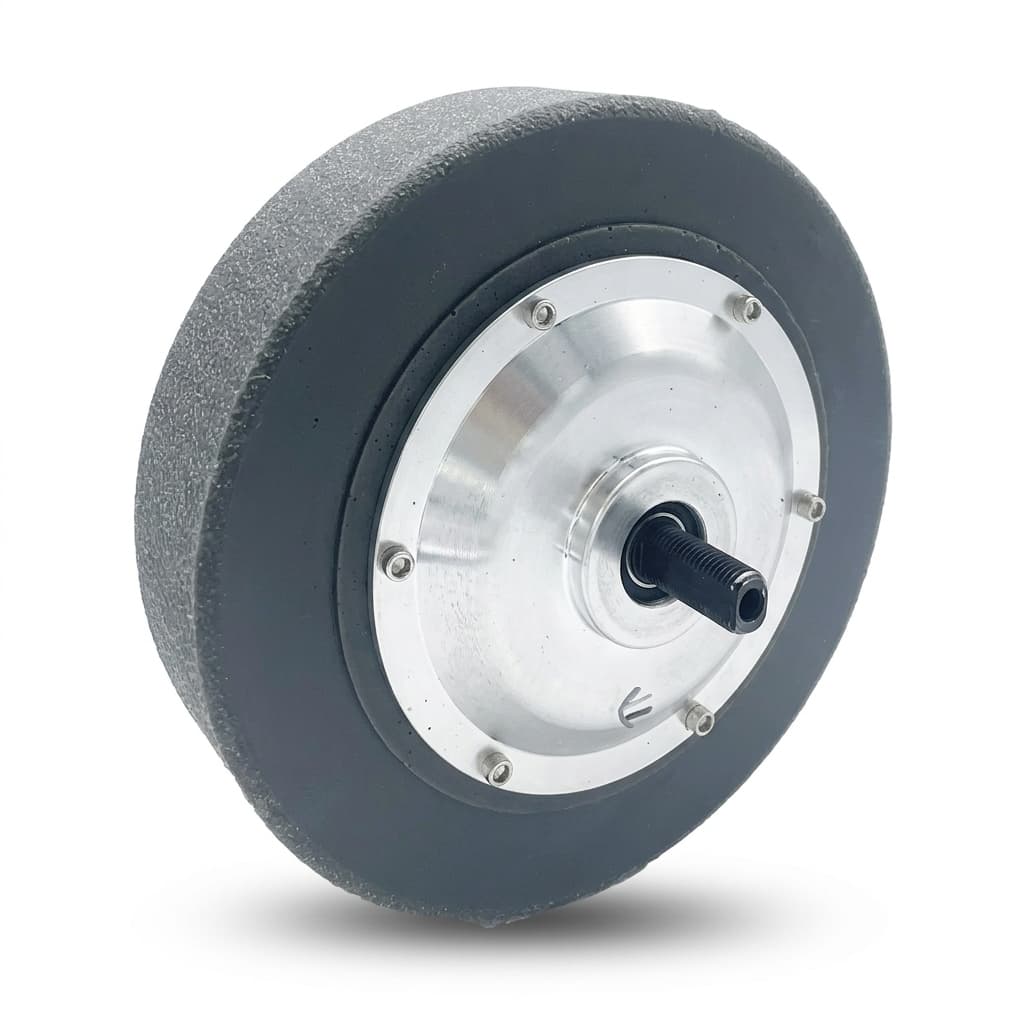
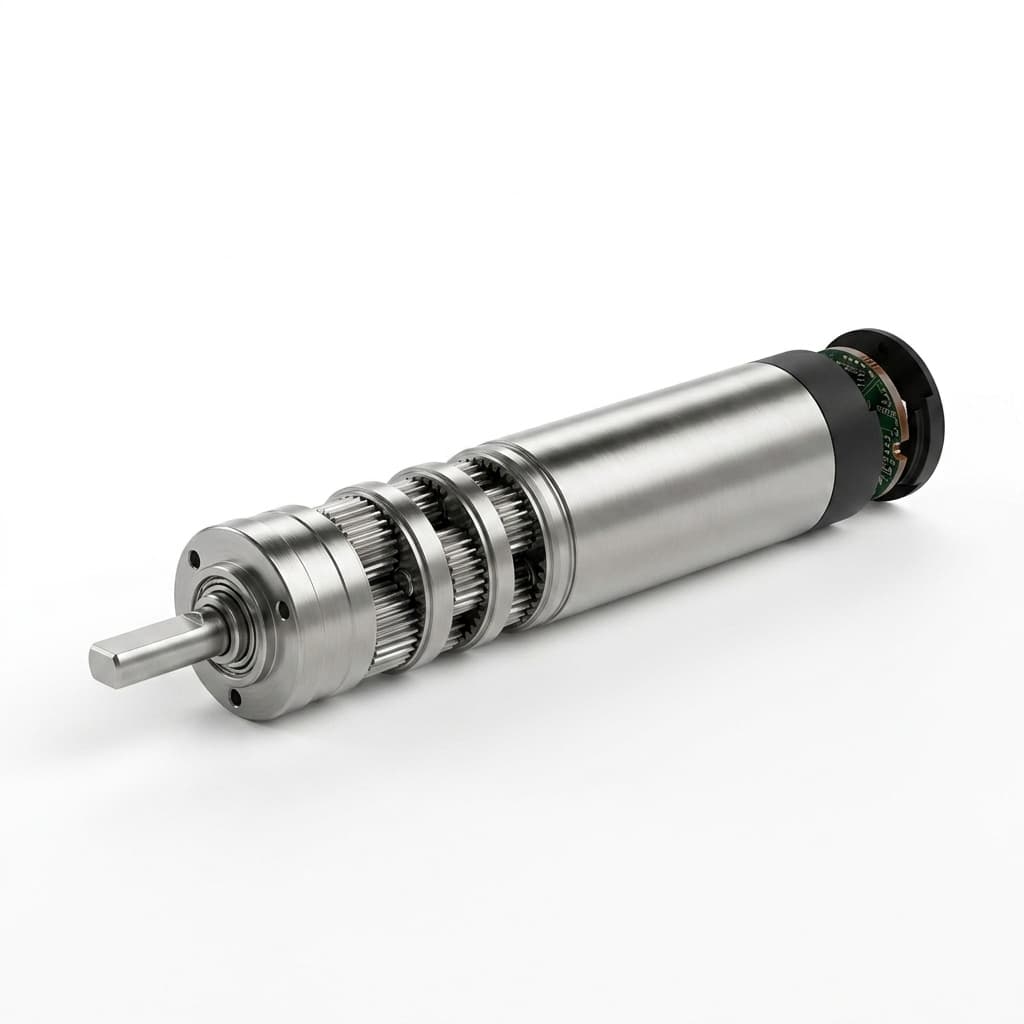
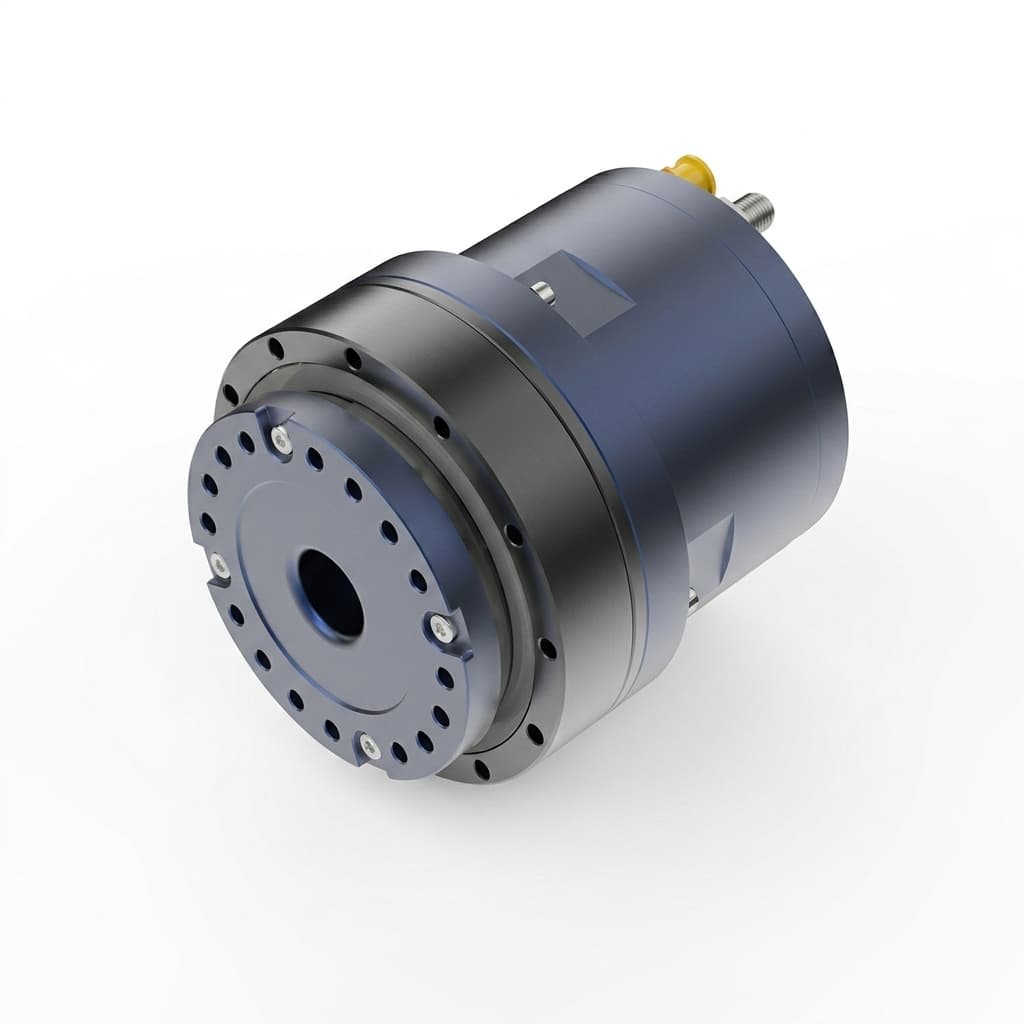
Product photographs help illustrate package and interface questions. They are not performance tests; the source table below distinguishes general selection methods from model-specific values that still need supplier confirmation.

High torque electric rotary actuator module for robot joint review
High-torque rotary actuator package used for torque and envelope discussion.
Zero backlash precision planetary rotary actuator output stage
Precision rotary output stage where backlash and stop accuracy must be datasheet-confirmed.
Integrated rotary joint actuator assembly for electric motion
Integrated robot-joint actuator example for interface and harness review.

These images illustrate actuator form factors. They do not identify a 12 VDC-rated model or establish its torque, duty, or interface limits; confirm those values on the candidate model’s datasheet.

Suitable and unsuitable use

Good fit

  • Battery or vehicle systems already standardized on 12 VDC.
  • Moderate torque, intermittent duty, and short cable runs.
  • Simple quarter-turn or half-turn positioning.

Poor fit

  • High current draw caused by high torque at 12 VDC.
  • Continuous or high-frequency cycling without thermal review.
  • Outdoor, washdown, or safety-stop requirements left undefined.

Selection methodology

MotionLoadElectricalInterfaceRFQ
StepInputsOutput
1. Bound the motionAngle, travel time, stop accuracy, duty cycleMotion profile and thermal exposure
2. Bound the loadOutput torque, breakaway torque, inertia, shock factorContinuous and peak torque target
3. Bound the electrical system12/24/48 VDC supply, controller, cable length, protectionVoltage and current feasibility screen
4. Bound integration riskMounting, shaft, enclosure, feedback, certification needsRFQ package and test plan

Evidence map for the 12V decision

The 12v electric rotary actuator decision should not be reduced to a voltage label. It combines the actuator category definition, electrical power limits, motion sizing inputs, and the enclosure boundary required by the actual application.

DefinitionNISTPower mathOpenStaxSelectionSuppliersEnvironmentNEMA12 VDC recommendation = category definition + power math + application inputs + environment boundary
SourceDate markerHow used hereLink
NIST CSRC Glossary, actuator termNIST SP 800-82 Rev. 3 source; checked June 17, 2026Defines actuator by source energy and motion/control function; supports treating 12 VDC as a supply variant.Open NIST CSRC Glossary, actuator term
Harmonic Drive FHA-C Mini 24VDC datasheet exampleManufacturer datasheet example; checked June 20, 2026Shows that supply voltage, torque, speed, gear ratio, and brake options are exact-model claims. The page uses this as a confirmation boundary, not as proof that every premium mini hollow actuator is or is not native 12V.Open Harmonic Drive FHA-C Mini 24VDC datasheet example
Oriental Motor DGII hollow rotary actuator product dataManufacturer product data; checked July 28, 2026Used as a public hollow rotary actuator example with model-specific bore and torque data. The page does not generalize those values to every 12V DC mini hollow rotary actuator.Open Oriental Motor DGII hollow rotary actuator product data
Industrial flexible-cable bend-radius guidanceCabling design guidelines; checked June 20, 2026Supports treating bend radius, strain relief, shielding, and torsion rating as cable-datasheet checks. Exact static and dynamic multipliers vary by cable construction and duty cycle.Open Industrial flexible-cable bend-radius guidance
Texas Instruments bulk capacitor sizing for DC motor drive applicationsApplication report SLVAFT0, July 2024; checked June 20, 2026Supports local bulk capacitance, separate logic power, and soft-start as mitigation patterns. Exact stall multiplier, capacitance, ESR, and undervoltage margin remain project-specific.Open Texas Instruments bulk capacitor sizing for DC motor drive applications
OpenStax Physics, electric power equationsOpenStax page published 2019; checked June 17, 2026Uses P = IV and V = IR to explain why equal input power at 12 VDC requires more current than 24/48 VDC.Open OpenStax Physics, electric power equations
Tolomatic electric actuator FAQSupplier FAQ checked June 17, 2026Lists orientation, distance, load, force, move time, cycle rate, and environment as basic application data for selection.Open Tolomatic electric actuator FAQ
Tolomatic motor integration guideSupplier guide checked June 17, 2026Frames continuous duty as time-average work that contributes to heat in the actuator and drive.Open Tolomatic motor integration guide
Oriental Motor rotary actuator selection calculationsCatalog reference checked June 17, 2026Documents load inertia, acceleration torque, required torque, speed-torque checking, and safety-factor steps for rotary selection.Open Oriental Motor rotary actuator selection calculations
ISO 5211:2026, industrial valve part-turn attachmentsPublished 2026; checked June 17, 2026Sets the boundary for industrial valve part-turn actuator attachments, flange dimensions, driving component dimensions, and interface torque references.Open ISO 5211:2026, industrial valve part-turn attachments
IEC public IP ratings explainer for IEC 60529IEC page checked June 17, 2026Separates solid-object/dust protection from liquid ingress protection, avoiding vague waterproof claims.Open IEC public IP ratings explainer for IEC 60529
NEMA enclosure type guideNEMA document checked June 17, 2026Separates indoor, outdoor, hose-directed water, windblown dust, and corrosion protection claims.Open NEMA enclosure type guide
OSHA Technical Manual, industrial robot safetyOSHA page checked June 17, 2026Supports the warning that unexpected robot movement, actuator energy, restricted spaces, and end-effector hazards remain integration risks.Open OSHA Technical Manual, industrial robot safety
Rockwell Automation Safe Brake Control application techniquePublication SAFETY-AT178C-EN-P, February 2021; checked June 17, 2026Frames holding brakes as devices for stationary disabled loads and separates holding from stopping a moving load.Open Rockwell Automation Safe Brake Control application technique
Victron Energy Wiring Unlimited, DC voltage drop theoryTechnical book page checked June 17, 2026Shows that cable resistance creates voltage drop and heat, and that 12 VDC loads need round-trip conductor review.Open Victron Energy Wiring Unlimited, DC voltage drop theory
JVL conversion and calculation note, voltage dropTechnical PDF checked June 17, 2026Uses a DC voltage-drop formula with the return conductor and copper resistivity around 0.01724 ohm mm2/m; supports the quick copper drop screen.Open JVL conversion and calculation note, voltage drop
Belimo DRC24A-7 rotary actuator datasheetDatasheet dated September 13, 2024; checked June 17, 2026Shows a real 24 V, 35 s/90 degree butterfly-valve actuator example and warns that non-constant torque and application release can be product-specific.Open Belimo DRC24A-7 rotary actuator datasheet
ISO/TS 16281:2008, rolling bearing load distributionStandard referenced; checked July 28, 2026Adds a modified reference life method for tilted or misaligned bearings alongside ISO 281. Its published scope does not establish applicability to every integrated or cross-roller actuator bearing.Open ISO/TS 16281:2008, rolling bearing load distribution
Moog Rekofa, Data Reliability with Slip Rings in Construction EquipmentMoog Rekofa white paper; checked September 30, 2026Explains how intermittent high-resistance events, impedance mismatch, and channel isolation affect signal reliability. It does not establish a universal contact material or service-life rating.Open Moog Rekofa, Data Reliability with Slip Rings in Construction Equipment
Texas Instruments, Brushless DC Motor FundamentalsApplication note checked September 30, 2026Defines back-EMF and torque constants as motor performance inputs. It supports checking the exact motor curve and current limits, but does not establish 12 VDC compatibility for a particular actuator.Open Texas Instruments, Brushless DC Motor Fundamentals

Voltage and alternative comparison

12 VDCCompact / mobiletorque / duty margin24 VDCFactory defaulttorque / duty margin48 VDCHigher margintorque / duty margin

Public supplier catalogs vary by model, so exact torque and duty values must be confirmed against datasheets. The comparison below keeps known decision logic separate from unknown vendor-specific limits.

OptionBest forWatch itemDecision note
12v 90 degree rotary actuator / 12 VDC electric rotary actuatorCompact quarter-turn machines, mobile equipment, prototypes, low-voltage cabinetsCurrent draw, thermal rise, torque headroom, cable dropUse when torque and duty remain moderate.
24 VDC electric rotary actuatorIndustrial control panels, moderate torque, repeatable automation cyclesPower supply sizing, brake voltage, controller compatibilityDefault shortlist for many factory automation projects.
48 VDC electric rotary actuatorHigher dynamic response, larger torque class, servo-like controlSafety design, drive selection, heat dissipationReview when 12/24 VDC has insufficient thermal or torque margin.
Pneumatic rotary actuatorSimple open-close motion where compressed air already existsAir supply, leakage, positioning precision, maintenanceCompare only when electrical position control is not required.

Need a model-specific 12 VDC check?

Send the load case, cable run, duty cycle, and candidate datasheet for an engineering review.

Request a model-specific review

90 degree quarter-turn boundary: valve, damper, robot joint, or hinge

The phrase 12v 90 degree rotary actuator can describe several different jobs. A valve buyer cares about part-turn attachment and breakaway torque, an HVAC buyer may mean a damper actuator, a robot builder needs inertia and feedback proof, a micro-package buyer needs envelope and heat limits, and a hinged-panel design may actually need a linear actuator geometry check.

ValveISO 5211Dampercatalog stopRobot jointinertia + feedbackHingegeometry first90 degree travel is shared language; interface proof changes by application.
ContextSource-backed factLimit / counterexampleDecision action
Industrial valve quarter-turn actuatorISO 5211:2026 covers part-turn actuator attachments for industrial valves, including flange dimensions, driving component dimensions, and interface torque reference values.It does not prove that a compact 12 VDC robot-joint actuator shares the same shaft, bearing, feedback, or housing requirements.If the load is a valve, request ISO 5211 flange size, drive coupling, breakaway torque, running torque, end torque, and supplier-purchaser interface agreement.
HVAC damper or butterfly-valve actuatorBelimo public datasheets show 24 V rotary actuators with 90 degree travel, published torque, running time, and application limits.A 24 V damper or butterfly-valve actuator is not evidence that a 12 V micro actuator can meet the same torque, speed, duty, or interface duty.Treat catalog damper/valve examples as application-specific benchmarks, not as universal micro actuator proof.
Robot joint or fixture indexerRotary sizing guidance requires inertia, acceleration torque, required torque, speed, stop accuracy, and position holding checks.There is no reliable public universal torque, backlash, life, or holding-brake dataset for every 12 V micro 90 degree rotary actuator.Ask for torque-speed curve, backlash, bearing loads, encoder resolution, brake behavior, life test conditions, and controller limits.
Linear actuator driving a hinged panelA hinge can move through 90 degrees while the purchased actuator is still linear, not rotary.A 90-degree travel request can hide a geometry problem; torque at the hinge changes with mounting angle and lever arm.Use a hinge-force calculation when the actuator pushes a lever or door, then shortlist rotary hardware only if direct rotary output is required.

Bearing & Load Capacity

Mechanical bearing configurations and moment load limits in hollow rotary tables

Hollow rotary actuators can see axial, radial, and overturning loads. Bearing type and capacity vary by design; a hollow shaft or robot-joint format does not establish the load rating. Check the exact model against the combined load and duty.

Deep-Groove Ball Bearing SupportRadial: OKAxial: LightMoment Load Capacity: Low (Susceptible to Tilt)Cross-Roller Bearing SupportAxial + thrust reviewHigh Moment Rigidity (Resists Cantilever Overturning)Cross-roller bearings support simultaneous radial, axial, and overturning moment loads.
Bearing configurationAxial or thrust load reviewMoment load reviewIdeal application scenario
Deep-groove ball bearing supportModel-specific; usually reviewed for light thrust casesModel-specific; poor fit for high offset or cantilever moment unless datasheet allows itSimple flat index plate, belt drive pulleys, direct axial coupling alignment.
Cross-roller bearing supportDatasheet-confirmed radial, axial, and moment ratings requiredMay support combined loads when the bearing and mounting are rated for them; verify limits and life for the exact modelDesigned rotary joints or indexers whose manufacturer rates the bearing for the required combined load.

Why 12 VDC can become a current and heat problem

For the same electrical input power, current rises as voltage falls. These examples use ideal input power only; real actuator efficiency, motor current limits, wiring resistance, and duty cycle still need datasheet confirmation.

12 VDC Supply System (Higher Current Review)12V SourceHigh I²R Heat (20A / 1.5mm²)ActuatorV_term: 9.6V (20% Drop)48 VDC Supply System (Lower Current Review)48V SourceLow Heat Loss (5A / 1.5mm²)ActuatorV_term: 47.4V (1.2% Drop)At equal power (240W input), wiring heat follows I²R, so lower voltage requires more current review.
Input power case12 VDC current24 VDC current48 VDC currentDecision implication
120 W input power10.0 A5.0 A2.5 ASmall battery machines may accept this, but connector and cable voltage drop must be checked.
240 W input power20.0 A10.0 A5.0 AAt this level, a 12 VDC shortlist needs explicit thermal and wiring review.
480 W input power40.0 A20.0 A10.0 AOften a trigger to review 24/48 VDC unless the system bus is fixed and well protected.

12 VDC wiring screen before the actuator shortlist

A 12v electric rotary actuator can be the right package, but the harness has to be sized from actual current and cable length. Public electrical theory supports the voltage-drop mechanism; exact connector resistance, stall current, fuse behavior, and allowable terminal voltage remain model-specific and are marked for RFQ confirmation.

The quick examples below use Vdrop = I x (2 x length x copper resistivity / conductor area) with a 20 C copper approximation. They are screening numbers only; connector resistance, conductor temperature, fuse/relay loss, and allowable terminal voltage remain pending until the exact harness is known.

Screening caseCurrentRound-trip copper resistanceVoltage dropDecision implication
120 W, 12 VDC, 2 m one-way, 1.5 mm2 copper10.0 A0.047 ohm0.47 V / 3.9%Usually workable as a screen, but connector and temperature losses still need RFQ confirmation.
120 W, 12 VDC, 5 m one-way, 0.75 mm2 copper10.0 A0.233 ohm2.33 V / 19.4%Strong warning: long, small-gauge 12 VDC harness can starve the actuator terminals.
240 W, 12 VDC, 5 m one-way, 1.5 mm2 copper20.0 A0.117 ohm2.33 V / 19.4%Often a reason to shorten cable, increase copper area, or review 24/48 VDC.
CheckDecision dataWhy it mattersRFQ action
Current from input powerPower target, supply voltage, peak and continuous currentAt equal input watts, 12 VDC draws twice the current of 24 VDC and four times the current of 48 VDC.Ask for peak current, continuous current, controller current limit, fuse size, and supply droop tolerance.
Round-trip cable resistanceOne-way cable length, conductor size, copper temperature, return pathDC voltage drop uses the full positive and negative conductor path; long 12 VDC runs can lose meaningful voltage before the actuator terminals.Calculate Vdrop = I x R for the complete circuit and confirm terminal voltage at peak current.
Connector and crimp lossesConnector count, contact rating, seal type, vibration exposureA low-resistance connector looks harmless at small current but can become a heat and voltage-drop point at higher 12 VDC current.Include connector series, pin current rating, harness drawing, and inspection requirements in the RFQ.
Protection and recoveryFuse, breaker, reverse polarity, stall current, restart behaviorA stalled rotary actuator can draw far more than a steady move case; protection must clear faults without nuisance trips.Confirm locked-rotor or stall current, protection coordination, and controller fault behavior with the supplier.

Holding torque, brake, and backdrive boundary

Many buyers ask whether a 12 VDC rotary actuator can hold position without power. The answer is not public-data universal. It depends on gearing, brake design, load direction, wear, duty cycle, and the safety consequence of a dropped or backdriven load.

TopicSource-backed boundaryPage decision
Holding a stationary loadRockwell frames motor holding brakes as devices for keeping a disabled stationary load in place, not as the primary way to stop moving inertia.Ask whether the 12 VDC rotary actuator uses self-locking gearing, an electromagnetic brake, or both.
Vertical or gravity-loaded axesSupplier brake guidance commonly treats vertical loads as a special case requiring brake and backdrive confirmation.Do not accept "holds position" as enough; request holding torque, brake voltage, engage time, release time, and positive-lock requirements.
Operator-under-load casesTolomatic cautions that a friction brake is not a positive lock for supporting heavy loads while an operator is under the load.Flag these as machine-safety cases requiring independent locking, guarding, or a different architecture.

Risk limits and controls

RiskImpactControl
Misusing 12 VDC as a universal requirementA 12 volt electric rotary actuator may need high current at elevated torque, creating heat and voltage-drop problems.Validate peak and continuous current, cable length, duty cycle, and allowable temperature rise.
Selecting on holding torque aloneThe actuator may meet static holding but miss acceleration, impact, or stop-position requirements.Specify running torque, breakaway torque, peak torque, travel time, and load inertia.
Ignoring enclosure and environmentOutdoor or washdown use can change seal design, corrosion protection, connector choice, and warranty scope.Define dust, splash, temperature, vibration, and cleaning exposure before model selection.
Assuming all rotary actuators are servo actuatorsOn/off units, analog-positioning units, and fieldbus servo units carry different controller and feedback requirements.Match control mode to stop accuracy, feedback, network, and commissioning workflow.
Treating duty cycle as only a controls settingContinuous or high-cycle operation increases actuator and drive heat, even when peak torque looks acceptable.Separate motion segments, calculate time-average work, and ask the supplier to confirm continuous ratings.
Confusing outdoor, washdown, and corrosion protectionAn outdoor enclosure class may not cover hose-directed water or corrosive cleaning exposure.Specify the expected NEMA or IP target, cleaning method, connector sealing, and corrosion exposure in the RFQ.
Letting a low voltage label soften safety reviewUnexpected robot motion, stored energy, vertical loads, and maintenance work inside a restricted space can still injure people even when the actuator supply is 12 VDC.Run the actuator inside the machine risk assessment, define lockout and guarding, and verify brake or stop functions with the exact model and controller.

Safety boundary: 12 VDC does not close the risk assessment

The public evidence supports a narrower conclusion: 12 VDC changes electrical current and wiring behavior, but it does not prove that a robot joint, end effector, or machine axis is safe. Any final safety claim is pending confirmation until the application, controller, guarding, brake, load, and maintenance procedure are reviewed together.

BoundaryEvidenceDecision rule
Robot or machine restricted spaceOSHA notes that workers may need to enter restricted spaces while actuators, valves, sensors, end effectors, or other energy sources are available.Treat actuator selection as part of the cell risk assessment, not just a component purchase.
Unexpected movementOSHA identifies unexpected robot movement, program changes, and component malfunction as contact and crushing hazards.Specify stop behavior, restart behavior, guarding, lockout, and controller fault handling before purchase.
Low-voltage powerThe public sources support lower-voltage current and wiring checks, but not a blanket claim that 12 VDC is safe by itself.Mark final safety category, brake proof, and compliance claims as pending confirmation until the exact application and model are known.

Environment boundary: indoor, outdoor, washdown, corrosion

Public enclosure definitions are useful for framing the RFQ, but a final actuator choice still needs the exact product rating, connector rating, shaft seal detail, and warranty scope.

ConditionSource boundaryPage decision
Indoor cabinet or protected machineNEMA Type 1/12-style thinking may be relevant.12 VDC can remain on the shortlist if torque, duty, and wiring are moderate.
Outdoor rain, sleet, windblown dust, ice exposureNEMA Type 3 families target outdoor weather exposure.Ask for outdoor-rated enclosure, connector, cable gland, and temperature limits.
Splash, coolant, or hose-directed washdownNEMA Type 4 covers hose-directed water; Type 4X adds corrosion protection.Do not assume an ordinary outdoor actuator is washdown-safe.

Illustrative screening scenarios

These hypothetical cases show how to frame a shortlist. They are not customer deployments or validated actuator selections.

Battery-powered access panel

12 VDC bus, 20-35 Nm output torque, 90 degree motion, micro package target, intermittent duty

Keep 12 VDC on the shortlist only if the named model’s curve covers peak and continuous torque and speed, the supply and cable run pass current and voltage-drop checks, and the duty stays within thermal limits.

Industrial diverter gate

24 VDC controls, 80-160 Nm torque, dusty environment, repeated cycles

Treat 12 VDC as a poor default; review 24 VDC or 48 VDC for thermal and current margin.

Robot fixture indexer

180 degree indexing, feedback required, moderate shock load

Prioritize backlash, feedback, holding brake, and controller compatibility over voltage label alone.

Quarter-turn valve retrofit

90 degree travel, valve stem interface, weather exposure, open-close control, unclear breakaway torque

Start with valve torque and interface standard evidence. A micro 12 V actuator remains pending confirmation until ISO 5211 fit, enclosure, and breakaway torque are proven.

Data sources and evidence boundary

Public sources support the selection method and first-pass checks. They cannot establish model-specific torque, duty, thermal, brake, enclosure, or service-life ratings; request the exact datasheet and test conditions before approving a candidate.

BoundaryDecision rule
What is known from public sourcesActuators convert energy into motion; rotary selection needs torque, inertia, speed, duty, and environment data.
What is model-specificPeak torque, continuous torque, backlash, brake holding, ingress rating, connector rating, and expected life require a named datasheet.
What is not reliably publicThere is no reliable public dataset showing a universal market share or default torque range for all 12 volt electric rotary actuators.
How this page handles uncertaintyThe tool gives a screening result only; unsupported or exact-performance requirements are routed to RFQ and engineering review.
Pending questionPublic statusWhy not concludedMinimum proof needed
Universal torque range for all 12v 90 degree rotary actuatorsNo reliable public data yetPublic catalogs are model families, not a normalized cross-vendor dataset for every compact 12 VDC quarter-turn actuator.Named model datasheet with torque-speed curve, duty rating, voltage/current limit, and test condition.
Backlash and stop accuracy for micro packagesPending confirmationBacklash depends on gear type, preload, wear, output bearing load, feedback loop, and stop strategy.Backlash specification, repeatability method, load condition, and inspection record for the exact model.
Power-off holding or brake suitabilityPending confirmationSelf-locking, friction brake, electromagnetic brake, and positive lock designs behave differently under gravity and shock.Holding torque, brake voltage, engage/release time, backdrive limit, and machine risk-assessment result.
Outdoor, washdown, or corrosion suitabilityPending confirmationIP and NEMA claims use different test boundaries; connector, shaft seal, cable exit, and corrosion material still matter.Exact IP/NEMA rating, connector rating, seal detail, material finish, cleaning method, and warranty scope.
12 VDC safety conclusionNo reliable public data yetLow voltage changes electrical design but does not remove motion, stored-energy, restricted-space, or end-effector hazards.Application risk assessment, stop behavior, lockout method, guarding, brake proof, and controller safety function.
Hollow shaft slip ring wear and contact resistance over life cycleModel-specific: rotating contact behavior affects signal reliabilityDynamic resistance, intermittent contact events, channel impedance, speed, current, and contamination can affect signal transfer. Limits and suitable contact materials vary by slip-ring design and application.Supplier data for the selected signal type, current, speed, environment, and life target, plus a dynamic resistance or transmission test under representative conditions.
Radial and axial bearing fatigue life under dynamic overturning momentsMethod applicability: ISO/TS 16281 supplements ISO 281 for specified bearing casesISO/TS 16281 adds load-distribution and life-calculation considerations for tilted or misaligned bearings within its scope. It does not automatically cover every integrated or cross-roller actuator bearing geometry.A life calculation using the exact bearing geometry and load spectrum; confirm with the bearing supplier whether ISO/TS 16281 applies and how it is used with ISO 281.
Native 12V DC winding availability for premium mini hollow actuatorsMotor and controller limits: confirm the 12 VDC operating curveA motor specified for 24 VDC is not guaranteed to meet its rated speed or torque from a 12 VDC supply. Back-EMF, winding resistance, driver limits, load, and thermal conditions all affect the operating point; custom winding changes those trade-offs.Custom winding datasheet showing the modified torque constant (Kt) and back-EMF constant (Ke), with thermal test results at 12V DC continuous operation.
Bulk capacitance sizing verification under transient startup or stall current sagsPending confirmationHarness wire length, logic board minimum voltage, and motor coil inductance differ in every mechanical joint, changing sag duration.Oscilloscope trace showing VIN sag remains above controller UVLO (Under-Voltage Lockout) during maximum dynamic stall, along with bulk capacitor ESR specifications.
  • Public industrial actuator selection guidance frames selection around motion, load, force or torque, move time, cycle rate, voltage, control, and environment. Vendor-specific catalog values remain datasheet-dependent.
  • Evidence boundary: The "12v dc mini hollow rotary actuator" evidence uses Harmonic Drive FHA-C Mini and Oriental Motor DGII data as public model-specific examples. Small-bore and torque figures such as 5.2-13.5 mm and 1.8-28 Nm are now treated as shortlist boundaries that still require exact datasheet, winding, thermal, and duty confirmation.
  • The 12V recommendation logic on this page is intentionally a screening model. It does not replace thermal testing, gearbox life validation, brake verification, or safety review.
  • Unknown values are not converted into invented chart data. When a requirement depends on an exact model, the page directs the buyer to RFQ and datasheet confirmation.

FAQ

Can I use a 12V hollow rotary actuator for my application?

A 12V hollow rotary actuator combines a supply-voltage requirement with a mechanical pass-through; neither tells you the other ratings. Confirm the candidate model’s bore drawing, speed-torque curve, continuous and peak torque, drive bus and phase-current limits, thermal data, and full motion profile. For cable or tube routing, also check outside diameter, bend radius, strain relief, and clearance through the complete rotation. Treat an unlisted 12V winding or bore combination as an RFQ question, not an assumed fit.

What should I confirm before choosing a 12 VDC rotary actuator?

Check the required torque and speed against the model’s 12 VDC curve, then verify peak and continuous current, cable voltage drop, driver limits, duty cycle, and thermal performance. Supply voltage by itself does not prove the actuator will meet the load.

What inputs are needed before requesting a quote?

Provide supply voltage, output torque, peak torque, angle, travel time, duty cycle, environment, mounting interface, shaft interface, feedback requirement, and annual volume.

Can a 12 VDC rotary actuator hold position without power?

Only if the design includes sufficient self-locking, a brake, or another holding mechanism. This must be confirmed for vertical loads or safety-related stops.

How should I screen voltage drop on a 12 VDC actuator?

Start with peak and continuous current, one-way cable length, conductor size, connector count, and terminal-voltage tolerance. Calculate round-trip circuit voltage drop with V = I x R, then confirm the actuator still sees enough voltage at peak current.

Is a holding brake the same as a safety lock?

No. Public brake guidance separates holding a stationary disabled load from stopping moving inertia, and supplier manuals often warn that friction brakes are not positive locks for operator-under-load cases. Treat brake behavior as datasheet and risk-assessment work.

When should I compare 12 VDC with 24 or 48 VDC?

Compare supplies when required power, current, cable length, connector capacity, thermal margin, or the installed bus makes 12 VDC difficult to support. Use the same load and motion profile for each option, then confirm the selected model’s ratings and controller compatibility.

What should I do if the calculator says custom path?

Send an RFQ with the full load case, cycle timing, target life, environment, interface drawing, and controller constraints. That is the minimum practical path to avoid under-sizing.

Can I use public catalog torque values as final proof?

Not by themselves. Public catalogs are useful for shortlisting, but final proof needs the exact model datasheet, duty-cycle rating, thermal assumptions, gearbox life data, mounting orientation, and supplier confirmation.

Does 90 degree travel mean the actuator follows ISO 5211?

Only for the relevant industrial valve attachment case. ISO 5211:2026 is useful when the actuator attaches to an industrial valve or intermediate support, but it does not define robot-joint packages, compact gearmotors, damper clamps, feedback electronics, or all 12 V micro actuator interfaces.

How should I check bearing life for a hollow rotary joint?

Bearing capacity and life depend on the exact bearing geometry, mounting, preload or clearance, combined radial and axial loads, overturning moment, speed, and duty. A cross-roller arrangement may support combined loads, but do not infer its rating or life from the actuator type. Request a supplier calculation for the named bearing and load spectrum. Confirm that any cited method, including ISO/TS 16281, applies to that bearing geometry and how it is used alongside ISO 281.

What are the main engineering risks when routing wires through a mini hollow rotary actuator?

The primary risks are cable twisting, insulation abrasion, and electrical noise. If rotating continuously, a slip ring is required; its contact resistance must be low to prevent voltage drops on low-voltage (12V) lines. For limited rotation, high-flex cables must be secured with adequate bend radii to avoid fatigue failure within the tight hollow aperture.

Can I run a standard 24V Harmonic Drive FHA-C Mini actuator in a 12V DC system?

Do not assume that a 24 VDC-rated actuator will meet the required speed or torque on 12 VDC. The operating point depends on the motor constants, load, winding resistance, driver voltage drop and current limit, gearbox, and thermal conditions. Request the exact 12 VDC torque-speed curve and continuous-duty limits; do not scale output performance from supply voltage alone.

What mechanical bend radius limits must I observe for wires inside a hollow actuator shaft?

Use the cable manufacturer datasheet as the controlling source. Static, continuous-flex, and torsion-rated cables can have different bend-radius multipliers, and hollow-shaft routing adds strain-relief, abrasion, shielding, and twist-cycle requirements. The RFQ should specify cable outer diameter, minimum bend radius, rotation angle, cycle count, and whether a slip ring is required.

How can I prevent microcontroller brown-out resets when a 12V DC motor starts or stalls?

First measure or request the startup and stall current profile for the exact actuator and driver. Common mitigations include local bulk capacitance at the driver, a separate regulated logic rail, soft-start or current limiting, short low-resistance supply wiring, and an oscilloscope check that the logic rail stays above undervoltage lockout during the worst move.

Related engineering paths

Engineering RFQ Email

[email protected]

Include torque-speed targets, annual volume, and timeline.

Lead Robotics Engineer

+86 18857971991

Direct technical conversation with our lead robotics engineer.