Identify the product family
A series number is not a torque unit or a compatibility standard. Check the 2G example and its limits below.
2G Engineering — 2000 Series Subsea Rotary Actuator ↗Estimate high torque rotary actuator peak/RMS torque and bearing moment, then compare real model ratings. Looking for 2000 series high torque rotary actuators? Identify the manufacturer and variant first.
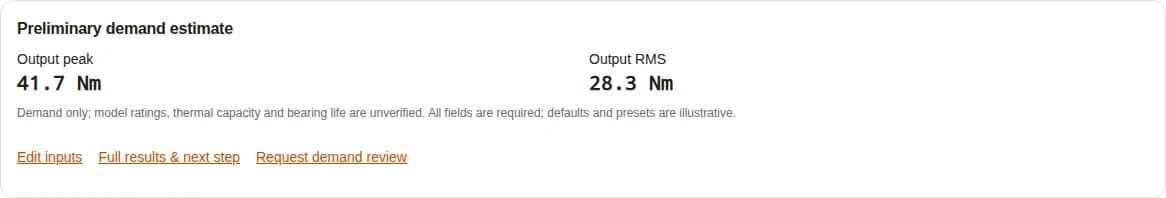
Output peak 41.7 Nm
Output RMS 28.3 Nm
Demand only; model ratings, thermal capacity and bearing life are unverified. All fields are required; defaults and presets are illustrative.
One positive-direction stroke with linear ramps, constant resisting torque and motor-energized dwell. Enter full-cycle data elsewhere for reversing axes.
Angular displacement per index or operational stroke. Range: 1–36000 deg.
Maximum rotational velocity at the actuator output flange. Range: 0.1–600 rpm.
Time required to accelerate from standstill to peak speed. Range: 0.02–10 s.
Time required to brake from peak speed to standstill. Range: 0.02–10 s.
Stationary or holding duration before next movement cycle. Range: 0–60 s.
Total inertia of payload, fixture, and turntable about rotation axis. Range: 0.001–50 kg·m².
Friction from external guide bearings, seals, and wiping seals. Range: 0–300 Nm.
Constant torque opposing this positive-direction stroke; same holding torque during dwell. Range: 0–1500 Nm.
Actuator transmission speed reduction ratio. Range: 1–300 :1.
Mechanical efficiency of harmonic, cycloidal, or planetary gear train. Range: 0.4–0.98 .
Internal servomotor rotor inertia (excluding gearhead). Range: 0.05–50 ×10⁻⁴ kg·m².
Motor-referred gear inertia from supplier; 0 excludes it until known. Range: 0–1000 ×10⁻⁴ kg·m².
Surrounding enclosure or ambient room temperature. Range: -20–75 °C.
Overhung radial load acting perpendicular to output shaft. Range: 0–40000 N.
Distance from mounting flange face to radial load point. Range: 0–1000 mm.
Thrust parallel to shaft axis; specify radial eccentricity separately. Range: 0–40000 N.
Radial offset of axial force from shaft center; zero for centered thrust. Range: 0–1000 mm.
Calculated demand is ready for comparison with supplier ratings. No selected model has been validated.
Accel: 41.7 Nm | Decel: 20.3 Nm
Duty Cycle: 42.9%
Lower screening ratio; verify drive limits
Applied moment; bearing capacity unverified
Motor Speed: 3000 rpm
Thermal capacity: not evaluated
Trapezoidal stroke: accel 0.250s, cruise 0.250s, decel 0.250s. Curves use independent normalized scales; dashed torque is signed around the midline.
Compare motor peak/RMS at calculated motor speed, reducer duty/peak duration, and combined bearing loads with the selected model. Export this estimate for supplier review.
A series number is not a torque unit or a compatibility standard. Check the 2G example and its limits below.
2G Engineering — 2000 Series Subsea Rotary Actuator ↗Peak checks require duration and speed; motor RMS includes ramp and holding phases. Neither alone qualifies a complete actuator.
Oriental Motor — Acceleration Torque and RMS Torque ↗This tool uses 5:1 and 10:1 screening bands. They are not universal stability limits; controller capabilities differ.
Oriental Motor — Servo Motor Selection Points ↗A cross-roller arrangement can carry multiple load directions. Actual load capacity still depends on size, mounting and the load spectrum.
THK — Cross-Roller Ring Structure and Features ↗A documented match is 2G Engineering — 2000 Series Subsea Rotary Actuator ↗. Its 2000 Series includes High Speed and High Torque variants. This is a manufacturer-specific subsea product family, not evidence of a universal 2000 Nm rating, 2-inch frame or interchangeable industrial package.
| Published item | 2G High Torque variant | Decision boundary |
|---|---|---|
| Continuous torque | 30 ft·lbf ≈ 40.7 Nm | From variant description; confirm duty and cooling |
| Peak torque | 50 ft·lbf ≈ 67.8 Nm | Peak duration and torque-speed curve require confirmation |
| Maximum speed | 9 rpm at 24 V | Do not assume maximum torque and speed are simultaneous |
| Environment and construction | Oil-filled, compensated subsea unit | An industrial joint needs separate environmental qualification |
| RJA drop-in equivalence | Unknown / not established | No verified matching model or interface comparison |
Conversion uses 1 ft·lbf = 1.35581795 Nm. The same manufacturer page’s family summary mixes values from different variants and contains differing temperature/depth summaries. Use the variant description for orientation and obtain the current configuration datasheet before procurement. Ratings above are a source snapshot, not a live stock or compatibility claim.
For part-number and interface identification, see 2G Engineering — 2000RHT High Torque datasheet, Rev D, p. 1 ↗. Its 2000RHT drawing is Rev D, dated October 30, 2015. Confirm the revision for your serial number before using its dimensions or pinout.
The solver models one positive-direction index followed by an energized holding dwell. Acceleration and deceleration are constant; friction and external resistance are nonnegative and fixed. The external torque also acts throughout the dwell. The return stroke, varying gravity, process transients and compliance are excluded. Oriental Motor — Acceleration Torque and RMS Torque ↗
| Quantity | Method | Limit |
|---|---|---|
| Velocity and ramps | ω = rpm × 2π/60; α = ωrequested / ramp time | Short strokes reduce achieved speed and ramp duration |
| Output phase torque | T = Jload × αsigned + Tfriction + Texternal; dwell = Texternal | Load inertia includes fixture and output-side moving mass |
| Motor phase torque | Tm = g(T) + (Jmotor + Jgear,input) × R × αsigned | g(T) = T/(Rη) for positive T; Tη/R for negative T during positive motion |
| Motor holding torque | Tm,hold ≈ Texternal/(Rη) | Conservative motoring-equivalent estimate; no self-locking or brake credit |
| RMS and peak | RMS = √(Σ Ti²ti / Σ ti); peak = max |Ti| | Calculated separately at output and motor; no safety factor added |
| Inertia screening ratio | λ = Jload / (R² × Jmotor) | Does not include gearhead inertia in this displayed load/rotor ratio |
Efficiency is a fixed bidirectional approximation. Real efficiency varies with speed, torque and temperature; standstill holding does not follow a power-efficiency model exactly. Gearhead input inertia defaults to zero until known and is explicitly flagged. These assumptions can materially change motor demand.
| Check | Data needed | Action when unknown |
|---|---|---|
| Motor peak / RMS / speed | Torque-speed curve, peak time, voltage, cooling, current limits | Request motor/drive sizing review |
| Reducer load and life | Rated duty, fatigue model, allowable peak and emergency torque | Run supplier equivalent-load and life calculation |
| Inertia and settling | Drive permissible inertia, stiffness and measured response | Simulate or bench-test the full mechanism |
| Bearing capacity | Radial/axial loads, moment vector, preload, mounting and life target | Use the actual bearing selection method |
| Thermal capacity | Ambient limits, mounting heat sink, winding and drive losses | Obtain manufacturer derating curves |
A computed estimate remains unqualified until these data are available. There is no universal 4500 rpm limit, 800 Nm bearing gate, 500% shock allowance or IEC-certified derating curve implemented here.
Request missing torque-speed curves and interface data| Option | Investigate | Tradeoff / alternative |
|---|---|---|
| Strain-wave | Backlash, torsional stiffness, flexspline fatigue, hollow bore | Check repeated peaks and life at your load spectrum |
| Cycloidal | Rated torque, rigidity, shock limits, output bearing arrangement | Compare mass, housing and input-stage integration |
| Precision planetary | Ratio stages, backlash, input speed, efficiency | Check whether output support or feedback must be external |
| Direct drive / external support | Motor size, current, cooling and bearing support | May remove gear backlash but change thermal and structural cost |
The tool’s reducer suggestion uses simple internal thresholds (450 Nm peak, 600 Nm moment, or speed/ratio bands). These are comparison heuristics without manufacturer qualification. Obtain candidates across architectures when packaging, life or precision dominates. No RJA weight-saving or torque-density percentage is established here.
Motion duty percentage is moving time divided by stroke-plus-dwell time. A stationary motor can still carry external torque and produce winding heat. Extending a loaded dwell can therefore retain substantial motor RMS demand. Output RMS describes this load cycle; it is not a reducer fatigue-life model.
Ambient temperature is recorded for supplier review. The tool does not calculate a permissible continuous torque percentage. Insulation class alone does not determine housing cooling, gearbox temperature, drive limits or usable torque. Oriental Motor — Acceleration Torque and RMS Torque ↗
The screening moment is M = Fr × L + Fa × e, with distances converted from millimetres to metres. L is the axial overhang of the radial force from the bearing reference plane; e is the radial eccentricity of the axial force. Magnitudes are added as a worst-case aligned approximation. With centered axial thrust, e = 0 and its moment term is zero, but thrust still loads the bearing. THK — Cross-Roller Ring Structure and Features ↗
For example, Fr = 2000 N at L = 100 mm gives 200 Nm. A centered 1000 N thrust adds no moment; an eccentricity of 40 mm adds 40 Nm. Axial/radial capacity, moment vectors, combined equivalent load, mounting bolts, stiffness and bearing life remain separate checks.
| Interface | Collect | Current evidence status |
|---|---|---|
| Mechanical | Pilot, bolt circle, shaft, flange, bore and permissible loads | Unknown until drawings are compared |
| Electrical / controls | Supply, pinout, current, protocol, feedback and brake logic | No fieldbus or encoder equivalence assumed |
| Environment | Pressure, fluid, seal, corrosion, lubricant and connector specification | 2G subsea use does not qualify an industrial alternative |
| Precision | Bidirectional accuracy, repeatability, stiffness and thermal drift | Encoder bit count is not installed positioning accuracy |
| Safety / service | Stopping behavior, brake duty, risk assessment and maintenance instructions | No certification, lifetime or maintenance-free claim inferred |
Output feedback can observe gearbox errors but cannot remove physical backlash or elasticity. Verify installed accuracy under actual load reversals. Request configuration-specific documentation for IP rating, functional safety and lubrication intervals.
These four hypothetical cases use the exact preset values in the tool, default ambient 30°C, centered axial thrust and gearhead input inertia excluded. Select the matching preset to inspect all assumptions. Results below are generated by the same solver, not measured performance or catalogue ratings.
| Example | Inputs: JL / R / stroke | Output peak / RMS (Nm) | Motor peak / RMS (Nm) | Action |
|---|---|---|---|---|
| Heavy industrial load (example) | 32.0 kg·m² / 160:1 / 180° | 437.4 / 221.4 | 3.87 / 1.83 | Add missing gear inertia; verify full cycle and ratings |
| Robotic Waist / Shoulder Joint (J1/J2) | 1.20 kg·m² / 101:1 / 90° | 113.8 / 92.9 | 1.89 / 1.22 | Add missing gear inertia; verify full cycle and ratings |
| High-Precision Rotary Table / Indexer | 0.65 kg·m² / 80:1 / 45° | 36.2 / 14.6 | 0.99 / 0.37 | Add missing gear inertia; verify full cycle and ratings |
| Heavy AGV / AMR Rotary Steer Drive | 0.40 kg·m² / 60:1 / 90° | 63.3 / 48.8 | 1.52 / 1.00 | Add missing gear inertia; verify full cycle and ratings |
The heavy industrial example is not a 2G rating. The shoulder example uses constant external torque for a single stroke; a real shoulder requires angle-dependent gravity and its return trajectory. The table example needs precision/settling validation; the steering example needs tire friction and shock measurements.
Ignoring reversal, variable gravity or stops may understate demand. Supply a signed full-cycle torque/speed trace before motor and brake selection.
Budget for adapters, external support, drives, cables, cooling and test work alongside actuator price. Ask for a configuration-specific quotation.
A torque match does not address hydrostatic pressure, corrosion or sealing. Retain the qualified subsea unit or commission environmental qualification of the alternative.
If supplier data are unavailable, export the estimate as a requirements brief and request the missing curves and drawings. A product recommendation remains pending; numerical output alone does not resolve that gap.
Published by Robot Joint Actuator. Guide first published November 12, 2026. Public sources reviewed . This is a documentation review, not empirical calibration, certification or test validation. Source pages may change; resolve the 2G family-summary inconsistencies with the supplier before purchase.
Drawing dated October 30, 2015: identifies 2000RHT, maximum torque and speed, shaft options and connectors. This historical drawing does not establish current availability or retrofit equivalence.
Manufacturer-specific series identity and High Torque variant ratings. The page has conflicting family summary values; confirm the exact configuration and latest datasheet.
Acceleration and time-weighted RMS calculation method; article updated April 27, 2022. It does not establish ratings for RJA or 2G products.
Permissible inertia and torque depend on the motor/drive. Its NX example permits ratios above this tool’s 10:1 screening heuristic.
Cross-roller rings can carry radial, axial and moment loads. Individual bearing ratings, mounting and load calculations remain necessary.
The tool equations and hypothetical scenarios are disclosed above. Architecture thresholds, constant efficiency and inertia screening bands are internal approximations. Unknown product ratings, safety evidence and retrofit equivalence remain explicitly unconfirmed.
No. A verified example is the 2G Engineering 2000 Series subsea family. Series numbers are manufacturer identifiers; request the full part number and torque units. This page does not establish a universal 2000 Nm or 2-inch standard.
No. Every tool preset is hypothetical application data. Gear ratio, rotor inertia and external loads are editable assumptions, not a manufacturer model database.
Compatibility is unconfirmed. Pressure compensation, sealing, corrosion, connectors, controls, shaft loads and torque-speed duty must all be reviewed. A dry industrial joint is not a qualified subsea replacement.
No. Separate catalogue maxima may describe different operating points. Obtain the torque-speed curve, permitted peak duration, voltage and thermal conditions for the exact variant.
Enter payload, fixture and all moving output-side components about this axis. Enter supplier motor-referred gearhead inertia separately. The zero gearhead default excludes an unknown quantity and is called out in the results.
The tool uses a triangular velocity profile at the entered acceleration rates. It reduces achieved speed and both ramp durations; the chart and results show effective rather than requested speed.
Motor and gearhead input inertia add acceleration torque and braking torque in their respective phases. Motor RMS is integrated from those signed phase torques, including the holding dwell.
Only a single positive stroke with constant resisting torque is modeled. A reversing joint needs both directions and angle-dependent gravity/inertia over the complete cycle in a multi-segment sizing model.
No. The 5:1 and 10:1 bands are early screening heuristics. Consult the selected drive’s permissible inertia and validate stiffness, resonance, tuning and settling time.
No. The axial moment term is axial force times its radial eccentricity. Centered thrust has zero eccentricity but still loads the bearing and must be checked with radial and moment loads together.
No. Ambient temperature is recorded and flagged for review outside the reference range. Continuous capacity requires manufacturer curves, mounting, cooling, winding and drive data; there is no universal derating percentage here.
No. It is a comparison starting point based on simple demand heuristics. Torque alone cannot choose architecture, bearing size, service life or part number.
No. RMS is useful for motor thermal screening under stated assumptions. Gearbox life may use a different equivalent torque exponent, speed weighting, shock factors and fatigue model supplied by the reducer manufacturer.
No. Determine stopping time, reflected kinetic energy, external torque, regeneration capacity and brake engagement behavior separately. Check the specific brake and reducer emergency ratings; a holding brake may not be a service brake.
Invalid fields show recovery guidance and suppress numeric results. Reset an example or ask for input help. If clipboard access fails, the sizing text opens for manual selection and copying.
Send the exported demand estimate, full cycle including return and stops, model/nameplate, torque-speed curves, flange drawing, force application points, voltage, cooling and environment. Response time, compatibility and pricing require confirmation.
Return to the calculator to export your requirements, then attach the full cycle and interface drawings for an engineering review.